Field notes on robotics, embodied AI, AI safety, and useful automation. An engineering perspective on investigating and building AI systems that improve economic productivity while maintaining clear safety boundaries.
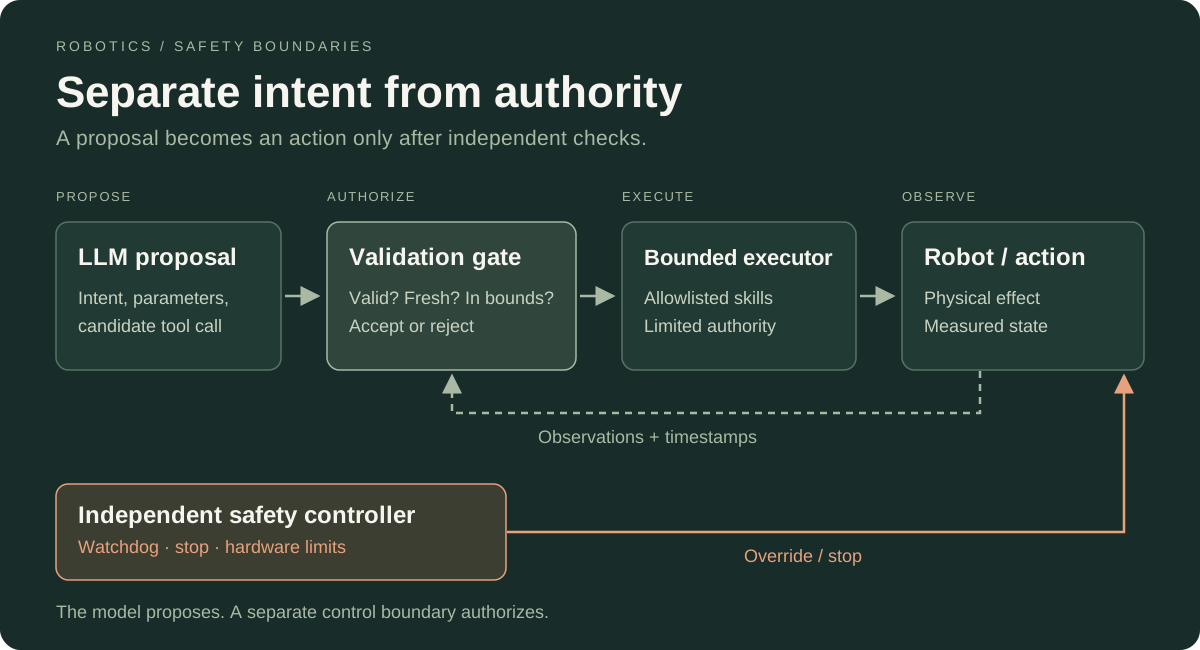
A practical framework for evaluating task proposals, action authority, state freshness, containment, and recovery in language-controlled robot systems.
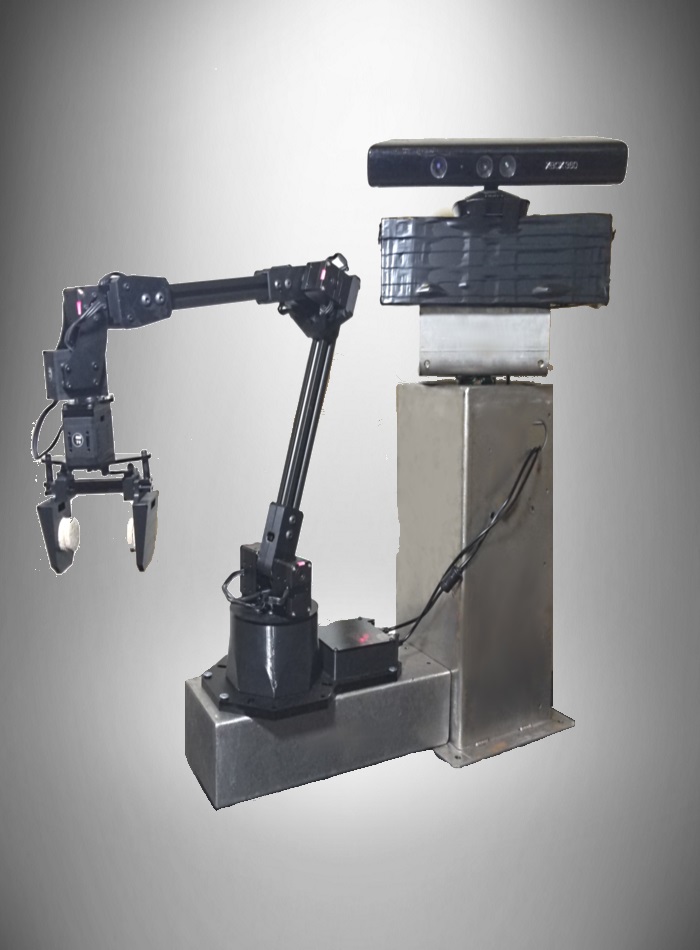
What a plywood repair task reveals about calibration, uncertainty, perception, and the interfaces that connect a useful model to a dependable physical system.
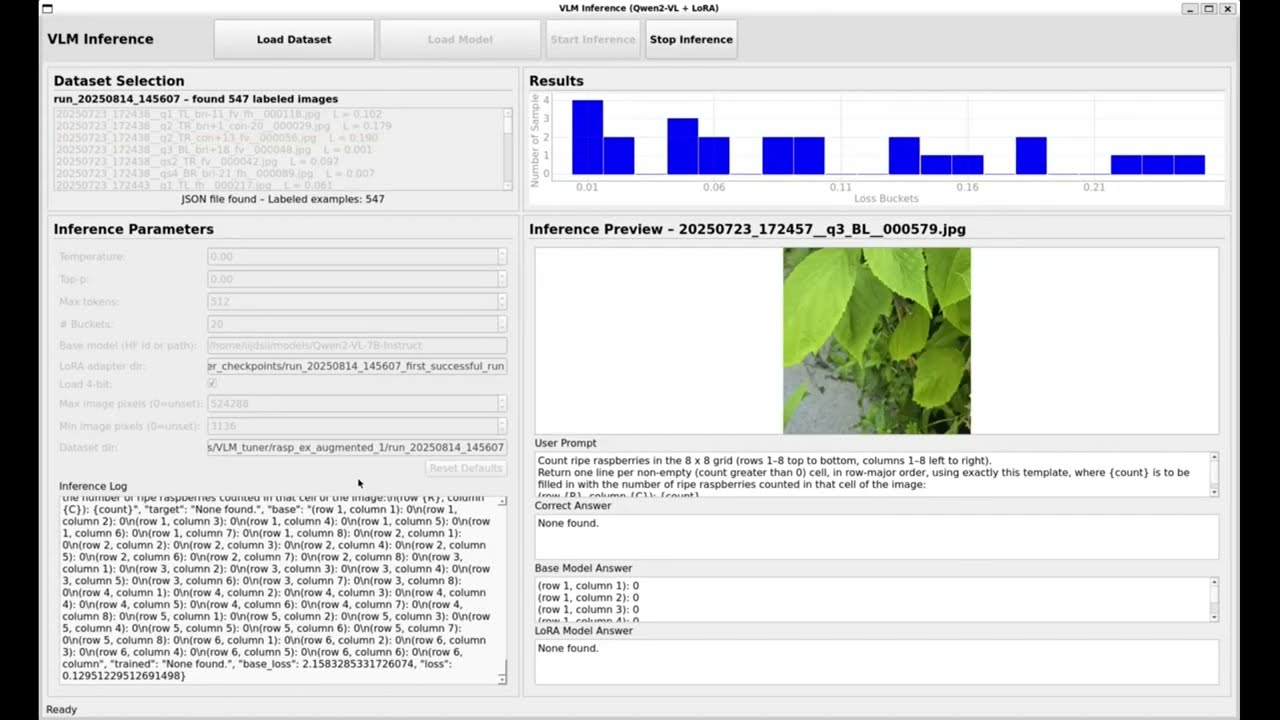
A source-backed look at AI productivity, with a worked engineering research workflow and a concrete way to account for verification, rework, and controlled release.
Robustness, cybersecurity, loss of control, and human misuse are different problems. A broader look at how to bound autonomous agents and preserve meaningful human authority.
These essays draw on my work across robotics, computer vision, and AI software. Worked examples are identified as illustrative, and research claims link to their sources. Follow new writing with RSS.